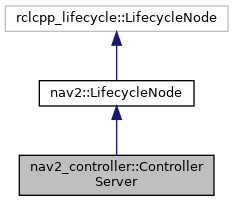
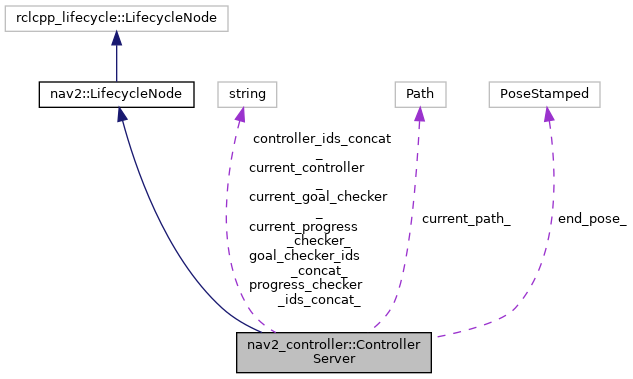
This class hosts variety of plugins of different algorithms to complete control tasks from the exposed FollowPath action server. More...
#include <nav2_controller/include/nav2_controller/controller_server.hpp>
Public Types | |
| using | ControllerMap = std::unordered_map< std::string, nav2_core::Controller::Ptr > |
| using | GoalCheckerMap = std::unordered_map< std::string, nav2_core::GoalChecker::Ptr > |
| using | ProgressCheckerMap = std::unordered_map< std::string, nav2_core::ProgressChecker::Ptr > |
| using | PathHandlerMap = std::unordered_map< std::string, nav2_core::PathHandler::Ptr > |
 Public Types inherited from nav2::LifecycleNode | |
| using | SharedPtr = std::shared_ptr< nav2::LifecycleNode > |
| using | WeakPtr = std::weak_ptr< nav2::LifecycleNode > |
| using | SharedConstPointer = std::shared_ptr< const nav2::LifecycleNode > |
Public Member Functions | |
| ControllerServer (const rclcpp::NodeOptions &options=rclcpp::NodeOptions()) | |
| Constructor for nav2_controller::ControllerServer. More... | |
| ~ControllerServer () | |
| Destructor for nav2_controller::ControllerServer. | |
| Public Member Functions inherited from nav2::LifecycleNode | |
| LifecycleNode (const std::string &node_name, const std::string &ns, const rclcpp::NodeOptions &options=rclcpp::NodeOptions()) | |
| A lifecycle node constructor. More... | |
| LifecycleNode (const std::string &node_name, const rclcpp::NodeOptions &options=rclcpp::NodeOptions()) | |
| A lifecycle node constructor with no namespace. More... | |
| template<typename ParameterT > | |
| ParameterT | declare_or_get_parameter (const std::string ¶meter_name, const ParameterDescriptor ¶meter_descriptor=ParameterDescriptor()) |
| Declares or gets a parameter with specified type (not value). If the parameter is already declared, returns its value; otherwise declares it with the specified type. More... | |
| template<typename ParamType > | |
| ParamType | declare_or_get_parameter (const std::string ¶meter_name, const ParamType &default_value, const ParameterDescriptor ¶meter_descriptor=ParameterDescriptor()) |
| Declares or gets a parameter. If the parameter is already declared, returns its value; otherwise declares it and returns the default value. More... | |
| template<typename MessageT , typename CallbackT > | |
| nav2::Subscription< MessageT >::SharedPtr | create_subscription (const std::string &topic_name, CallbackT &&callback, const rclcpp::QoS &qos=nav2::qos::StandardTopicQoS(), const rclcpp::CallbackGroup::SharedPtr &callback_group=nullptr) |
| Create a subscription to a topic using Nav2 QoS profiles and SubscriptionOptions. More... | |
| template<typename MessageT > | |
| nav2::Publisher< MessageT >::SharedPtr | create_publisher (const std::string &topic_name, const rclcpp::QoS &qos=nav2::qos::StandardTopicQoS(), const rclcpp::CallbackGroup::SharedPtr &callback_group=nullptr, rclcpp::PublisherMatchedCallbackType matched_callback=nullptr) |
| Create a publisher to a topic using Nav2 QoS profiles and PublisherOptions. More... | |
| template<typename ServiceT > | |
| nav2::ServiceClient< ServiceT >::SharedPtr | create_client (const std::string &service_name, bool use_internal_executor=false) |
| Create a ServiceClient to interface with a service. More... | |
| template<typename ServiceT > | |
| nav2::ServiceServer< ServiceT >::SharedPtr | create_service (const std::string &service_name, typename nav2::ServiceServer< ServiceT >::CallbackType cb, rclcpp::CallbackGroup::SharedPtr callback_group=nullptr) |
| Create a ServiceServer to host with a service. More... | |
| template<typename DurationRepT , typename DurationT , typename CallbackT > | |
| rclcpp::GenericTimer< CallbackT >::SharedPtr | create_timer (std::chrono::duration< DurationRepT, DurationT > period, CallbackT callback, rclcpp::CallbackGroup::SharedPtr group=nullptr) |
| Create a sim-time-aware timer for Nav2 lifecycle nodes. More... | |
| template<typename ActionT > | |
| nav2::SimpleActionServer< ActionT >::SharedPtr | create_action_server (const std::string &action_name, typename nav2::SimpleActionServer< ActionT >::ExecuteCallback execute_callback, typename nav2::SimpleActionServer< ActionT >::GoalReceivedCallback goal_received_callback=nullptr, typename nav2::SimpleActionServer< ActionT >::CompletionCallback compl_cb=nullptr, std::chrono::milliseconds server_timeout=std::chrono::milliseconds(500), bool spin_thread=false, const bool realtime=false) |
| Create a SimpleActionServer to host with an action. More... | |
| template<typename ActionT > | |
| nav2::ActionClient< ActionT >::SharedPtr | create_action_client (const std::string &action_name, rclcpp::CallbackGroup::SharedPtr callback_group=nullptr) |
| Create a ActionClient to call an action using. More... | |
| nav2::LifecycleNode::SharedPtr | shared_from_this () |
| Get a shared pointer of this. | |
| nav2::LifecycleNode::WeakPtr | weak_from_this () |
| Get a shared pointer of this. | |
| nav2::CallbackReturn | on_error (const rclcpp_lifecycle::State &) |
| Abstracted on_error state transition callback, since unimplemented as of 2020 in the managed ROS2 node state machine. More... | |
| void | autostart () |
| Automatically configure and active the node. | |
| virtual void | on_rcl_preshutdown () |
| Perform preshutdown activities before our Context is shutdown. Note that this is related to our Context's shutdown sequence, not the lifecycle node state machine. | |
| void | createBond () |
| Create bond connection to lifecycle manager. | |
| void | destroyBond () |
| Destroy bond connection to lifecycle manager. | |
Protected Types | |
| using | Action = nav2_msgs::action::FollowPath |
| using | ActionServer = nav2::SimpleActionServer< Action > |
Protected Member Functions | |
| nav2::CallbackReturn | on_configure (const rclcpp_lifecycle::State &state) override |
| Configures controller parameters and member variables. More... | |
| nav2::CallbackReturn | on_activate (const rclcpp_lifecycle::State &state) override |
| Activates member variables. More... | |
| nav2::CallbackReturn | on_deactivate (const rclcpp_lifecycle::State &state) override |
| Deactivates member variables. More... | |
| nav2::CallbackReturn | on_cleanup (const rclcpp_lifecycle::State &state) override |
| Calls clean up states and resets member variables. More... | |
| nav2::CallbackReturn | on_shutdown (const rclcpp_lifecycle::State &state) override |
| Called when in Shutdown state. More... | |
| bool | goalReceived (std::shared_ptr< const Action::Goal > goal) |
| Goal received callback to validate a new goal before acceptance. More... | |
| void | computeControl () |
| FollowPath action server callback. Handles action server updates and spins server until goal is reached. More... | |
| bool | findControllerId (const std::string &c_name, std::string &name) |
| Find the valid controller ID name for the given request. More... | |
| bool | findGoalCheckerId (const std::string &c_name, std::string &name) |
| Find the valid goal checker ID name for the specified parameter. More... | |
| bool | findProgressCheckerId (const std::string &c_name, std::string &name) |
| Find the valid progress checker ID name for the specified parameter. More... | |
| bool | findPathHandlerId (const std::string &c_name, std::string &name) |
| Find the valid path handler ID name for the specified parameter. More... | |
| void | setPlannerPath (const nav_msgs::msg::Path &path) |
| Assigns path to controller. More... | |
| void | transformedPlanAndGoal (const geometry_msgs::msg::PoseStamped ¤t_robot_pose) |
| Refreshes transformed_global_plan_ and transformed_end_pose_ for the current cycle. More... | |
| void | computeAndPublishVelocity (const geometry_msgs::msg::PoseStamped ¤t_robot_pose) |
| Calculates velocity and publishes to "cmd_vel" topic. More... | |
| void | updateGlobalPath () |
| Calls setPlannerPath method with an updated path received from action server. | |
| void | publishVelocity (const geometry_msgs::msg::TwistStamped &velocity) |
| Calls velocity publisher to publish the velocity on "cmd_vel" topic. More... | |
| void | publishZeroVelocity () |
| Calls velocity publisher to publish zero velocity. | |
| void | onGoalExit (bool force_stop) |
| Called on goal exit. | |
| double | waitForCostmap () |
| Wait for costmap to become current, with timeout. More... | |
| bool | isGoalReached (const geometry_msgs::msg::PoseStamped ¤t_robot_pose) |
| Checks if goal is reached. More... | |
| geometry_msgs::msg::PoseStamped | getCurrentRobotPose () |
| Obtain the current pose of the robot in the costmap frame. More... | |
| double | getThresholdedVelocity (double velocity, double threshold) |
| get the thresholded velocity More... | |
| geometry_msgs::msg::Twist | getThresholdedTwist (const geometry_msgs::msg::Twist &twist) |
| get the thresholded Twist More... | |
| Protected Member Functions inherited from nav2::LifecycleNode | |
| void | printLifecycleNodeNotification () |
| Print notifications for lifecycle node. | |
| void | register_rcl_preshutdown_callback () |
| void | runCleanups () |
Protected Attributes | |
| ActionServer::SharedPtr | action_server_ |
| std::shared_ptr< nav2_costmap_2d::Costmap2DROS > | costmap_ros_ |
| std::unique_ptr< nav2::NodeThread > | costmap_thread_ |
| std::unique_ptr< nav2_util::OdomSmoother > | odom_sub_ |
| std::unique_ptr< nav2_util::TwistPublisher > | vel_publisher_ |
| nav2::Subscription< nav2_msgs::msg::SpeedLimit >::SharedPtr | speed_limit_sub_ |
| nav2::Publisher< nav2_msgs::msg::TrackingFeedback >::SharedPtr | tracking_feedback_pub_ |
| pluginlib::ClassLoader< nav2_core::ProgressChecker > | progress_checker_loader_ |
| ProgressCheckerMap | progress_checkers_ |
| std::string | progress_checker_ids_concat_ |
| std::string | current_progress_checker_ |
| pluginlib::ClassLoader< nav2_core::GoalChecker > | goal_checker_loader_ |
| GoalCheckerMap | goal_checkers_ |
| std::string | goal_checker_ids_concat_ |
| std::string | current_goal_checker_ |
| pluginlib::ClassLoader< nav2_core::Controller > | lp_loader_ |
| ControllerMap | controllers_ |
| std::string | controller_ids_concat_ |
| std::string | current_controller_ |
| pluginlib::ClassLoader< nav2_core::PathHandler > | path_handler_loader_ |
| PathHandlerMap | path_handlers_ |
| std::string | path_handler_ids_concat_ |
| std::string | current_path_handler_ |
| size_t | start_index_ |
| geometry_msgs::msg::PoseStamped | end_pose_ |
| geometry_msgs::msg::PoseStamped | transformed_end_pose_ |
| rclcpp::Time | last_valid_cmd_time_ |
| nav_msgs::msg::Path | current_path_ |
| nav_msgs::msg::Path | transformed_global_plan_ |
| std::unique_ptr< nav2_controller::ParameterHandler > | param_handler_ |
| Parameters * | params_ |
| nav2::Publisher< nav_msgs::msg::Path >::SharedPtr | transformed_plan_pub_ |
| double | transform_tolerance_ |
| Protected Attributes inherited from nav2::LifecycleNode | |
| std::unique_ptr< rclcpp::PreShutdownCallbackHandle > | rcl_preshutdown_cb_handle_ {nullptr} |
| std::shared_ptr< bond::Bond > | bond_ {nullptr} |
| double | bond_heartbeat_period {0.1} |
| rclcpp::TimerBase::SharedPtr | autostart_timer_ |
Detailed Description
This class hosts variety of plugins of different algorithms to complete control tasks from the exposed FollowPath action server.
Definition at line 52 of file controller_server.hpp.
Constructor & Destructor Documentation
◆ ControllerServer()
|
explicit |
Constructor for nav2_controller::ControllerServer.
- Parameters
-
options Additional options to control creation of the node.
Definition at line 39 of file controller_server.cpp.
Member Function Documentation
◆ computeAndPublishVelocity()
|
protected |
Calculates velocity and publishes to "cmd_vel" topic.
- Parameters
-
current_robot_pose Pose of the robot to be used as reference
Definition at line 742 of file controller_server.cpp.
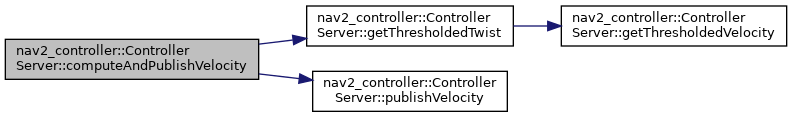
References getThresholdedTwist(), and publishVelocity().
Referenced by computeControl().

◆ computeControl()
|
protected |
FollowPath action server callback. Handles action server updates and spins server until goal is reached.
Provides global path to controller received from action client. Twist velocities for the robot are calculated and published using controller at the specified rate till the goal is reached.
- Exceptions
-
nav2_core::PlannerException
Definition at line 496 of file controller_server.cpp.
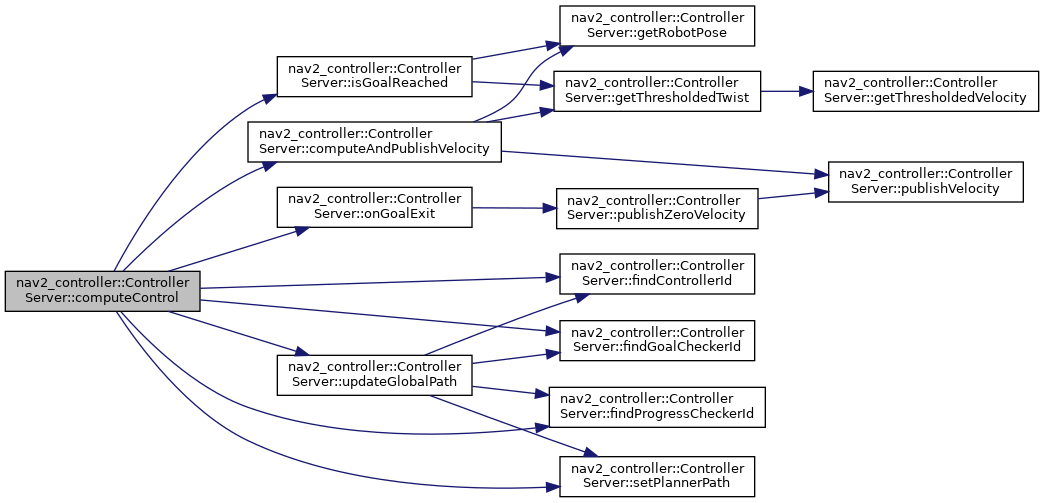
References computeAndPublishVelocity(), findControllerId(), findGoalCheckerId(), findPathHandlerId(), findProgressCheckerId(), getCurrentRobotPose(), isGoalReached(), onGoalExit(), setPlannerPath(), transformedPlanAndGoal(), updateGlobalPath(), and waitForCostmap().
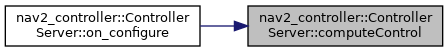
Referenced by on_configure().
◆ findControllerId()
|
protected |
Find the valid controller ID name for the given request.
- Parameters
-
c_name The requested controller name name Reference to the name to use for control if any valid available
- Returns
- bool Whether it found a valid controller to use
Definition at line 334 of file controller_server.cpp.
Referenced by computeControl(), goalReceived(), and updateGlobalPath().

◆ findGoalCheckerId()
|
protected |
Find the valid goal checker ID name for the specified parameter.
- Parameters
-
c_name The goal checker name name Reference to the name to use for goal checking if any valid available
- Returns
- bool Whether it found a valid goal checker to use
Definition at line 360 of file controller_server.cpp.
Referenced by computeControl(), goalReceived(), and updateGlobalPath().

◆ findPathHandlerId()
|
protected |
Find the valid path handler ID name for the specified parameter.
- Parameters
-
c_name The path handler name name Reference to the name to use for path handling if any valid available
- Returns
- bool Whether it found a valid path handler to use
Definition at line 428 of file controller_server.cpp.
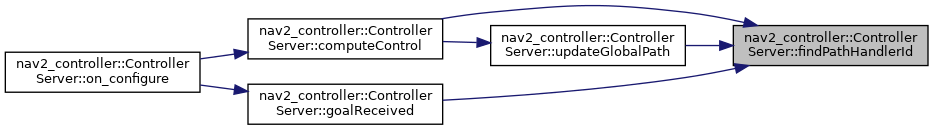
Referenced by computeControl(), goalReceived(), and updateGlobalPath().
◆ findProgressCheckerId()
|
protected |
Find the valid progress checker ID name for the specified parameter.
- Parameters
-
c_name The progress checker name name Reference to the name to use for progress checking if any valid available
- Returns
- bool Whether it found a valid progress checker to use
Definition at line 386 of file controller_server.cpp.
Referenced by computeControl(), goalReceived(), and updateGlobalPath().

◆ getCurrentRobotPose()
|
protected |
Obtain the current pose of the robot in the costmap frame.
- Returns
- Current robot pose
- Exceptions
-
nav2_core::ControllerTFError if the pose cannot be obtained or its transform is stale
Definition at line 970 of file controller_server.cpp.
Referenced by computeControl().

◆ getThresholdedTwist()
|
inlineprotected |
get the thresholded Twist
- Parameters
-
Twist The current Twist from odometry
- Returns
- Twist Twist after thresholds applied
Definition at line 246 of file controller_server.hpp.
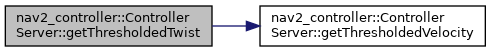
References getThresholdedVelocity().
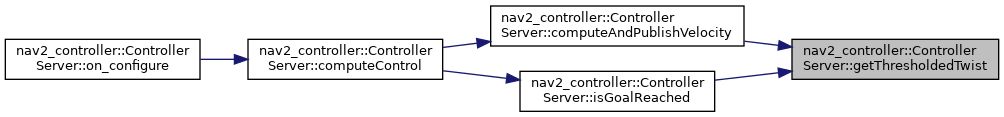
Referenced by computeAndPublishVelocity(), and isGoalReached().
◆ getThresholdedVelocity()
|
inlineprotected |
get the thresholded velocity
- Parameters
-
velocity The current velocity from odometry threshold The minimum velocity to return non-zero
- Returns
- double velocity value
Definition at line 236 of file controller_server.hpp.
Referenced by getThresholdedTwist().

◆ goalReceived()
|
protected |
Goal received callback to validate a new goal before acceptance.
- Parameters
-
goal The incoming goal to validate
- Returns
- true if goal should be accepted, false to reject
Definition at line 454 of file controller_server.cpp.
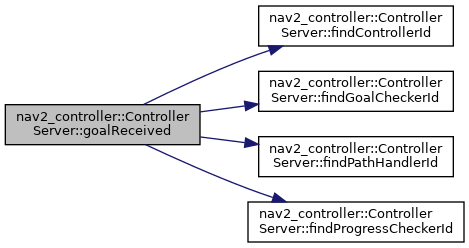
References findControllerId(), findGoalCheckerId(), findPathHandlerId(), and findProgressCheckerId().
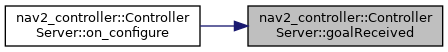
Referenced by on_configure().
◆ isGoalReached()
|
protected |
Checks if goal is reached.
- Parameters
-
current_robot_pose The robot pose to be used as reference
- Returns
- true or false
Definition at line 961 of file controller_server.cpp.
References getThresholdedTwist().
Referenced by computeControl().


◆ on_activate()
|
overrideprotected |
Activates member variables.
Activates controller, costmap, velocity publisher and follow path action server
- Parameters
-
state LifeCycle Node's state
- Returns
- Success or Failure
Definition at line 226 of file controller_server.cpp.
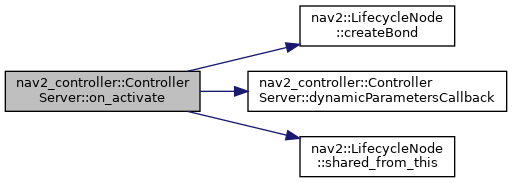
References nav2::LifecycleNode::createBond(), and nav2::LifecycleNode::shared_from_this().
◆ on_cleanup()
|
overrideprotected |
Calls clean up states and resets member variables.
Controller and costmap clean up state is called, and resets rest of the variables
- Parameters
-
state LifeCycle Node's state
- Returns
- Success or Failure
Definition at line 297 of file controller_server.cpp.
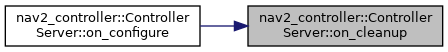
Referenced by on_configure().
◆ on_configure()
|
overrideprotected |
Configures controller parameters and member variables.
Configures controller plugin and costmap; Initialize odom subscriber, velocity publisher and follow path action server.
- Parameters
-
state LifeCycle Node's state
- Returns
- Success or Failure
- Exceptions
-
pluginlib::PluginlibException When failed to initialize controller plugin
Definition at line 65 of file controller_server.cpp.
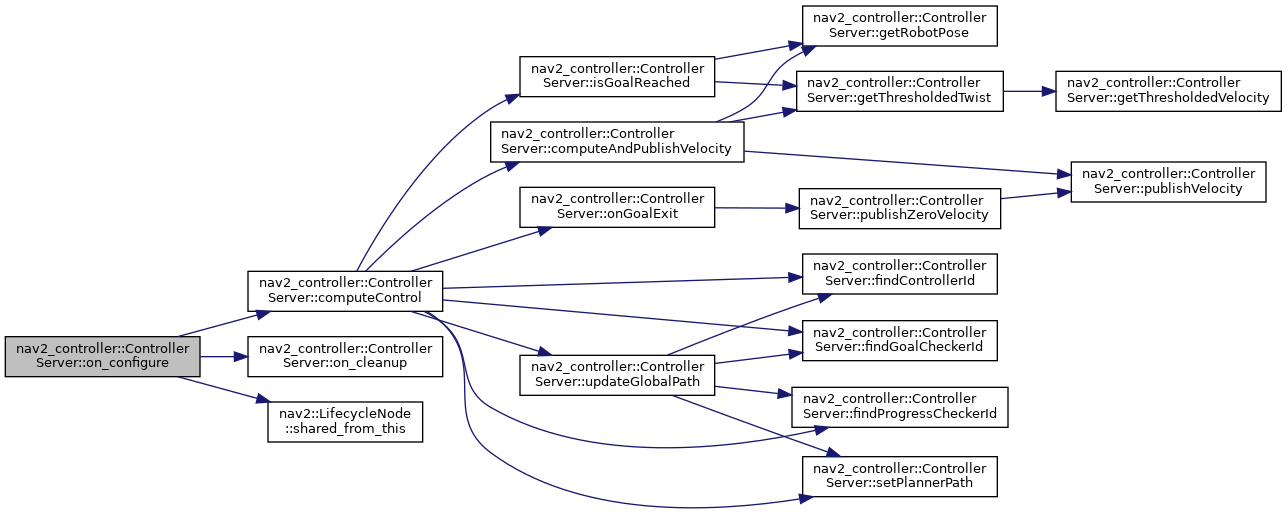
References computeControl(), goalReceived(), on_cleanup(), and nav2::LifecycleNode::shared_from_this().
◆ on_deactivate()
|
overrideprotected |
Deactivates member variables.
Deactivates follow path action server, controller, costmap and velocity publisher. Before calling deactivate state, velocity is being set to zero.
- Parameters
-
state LifeCycle Node's state
- Returns
- Success or Failure
Definition at line 265 of file controller_server.cpp.
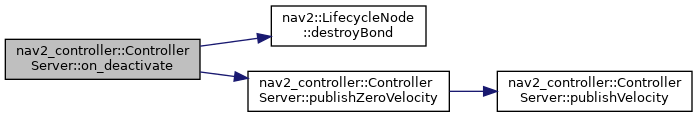
References nav2::LifecycleNode::destroyBond(), and publishZeroVelocity().
◆ on_shutdown()
|
overrideprotected |
Called when in Shutdown state.
- Parameters
-
state LifeCycle Node's state
- Returns
- Success or Failure
Definition at line 328 of file controller_server.cpp.
◆ publishVelocity()
|
protected |
Calls velocity publisher to publish the velocity on "cmd_vel" topic.
- Parameters
-
velocity Twist velocity to be published
Definition at line 923 of file controller_server.cpp.
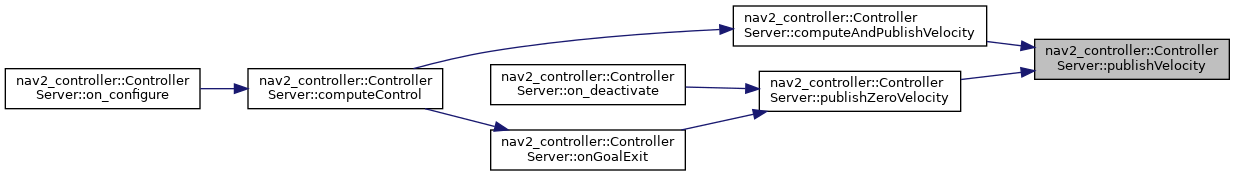
Referenced by computeAndPublishVelocity(), and publishZeroVelocity().
◆ setPlannerPath()
|
protected |
Assigns path to controller.
- Parameters
-
path Path received from action server
Definition at line 697 of file controller_server.cpp.
Referenced by computeControl(), and updateGlobalPath().

◆ transformedPlanAndGoal()
|
protected |
Refreshes transformed_global_plan_ and transformed_end_pose_ for the current cycle.
- Parameters
-
current_robot_pose Pose of the robot to be used as reference
- Exceptions
-
nav2_core::ControllerTFError if the robot pose or end pose cannot be obtained
Definition at line 720 of file controller_server.cpp.
Referenced by computeControl().

◆ waitForCostmap()
|
protected |
Wait for costmap to become current, with timeout.
- Returns
- Duration in seconds spent waiting for the costmap (0.0 if already current)
- Exceptions
-
nav2_core::ControllerTimedOut if costmap update times out
Definition at line 680 of file controller_server.cpp.
Referenced by computeControl().

The documentation for this class was generated from the following files:
- nav2_controller/include/nav2_controller/controller_server.hpp
- nav2_controller/src/controller_server.cpp
