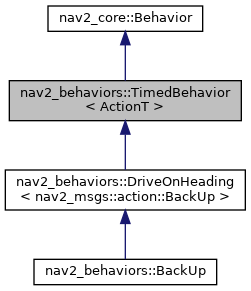
Inheritance diagram for nav2_behaviors::TimedBehavior< ActionT >:
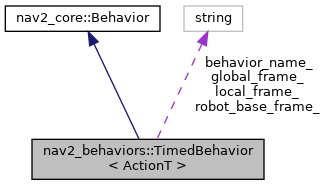
Collaboration diagram for nav2_behaviors::TimedBehavior< ActionT >:
Public Types | |
| using | ActionServer = nav2::SimpleActionServer< ActionT > |
 Public Types inherited from nav2_core::Behavior | |
| using | Ptr = std::shared_ptr< Behavior > |
Public Member Functions | |
| TimedBehavior () | |
| A TimedBehavior constructor. | |
| virtual ResultStatus | onRun (const std::shared_ptr< const typename ActionT::Goal > command)=0 |
| virtual ResultStatus | onCycleUpdate ()=0 |
| virtual void | onConfigure () |
| virtual void | onCleanup () |
| virtual void | onActionCompletion (std::shared_ptr< typename ActionT::Result >) |
| void | configure (const nav2::LifecycleNode::WeakPtr &parent, const std::string &name, nav2::TransformBuffer::SharedPtr tf, std::shared_ptr< nav2_costmap_2d::CostmapTopicCollisionChecker > local_collision_checker, std::shared_ptr< nav2_costmap_2d::CostmapTopicCollisionChecker > global_collision_checker) override |
| void | cleanup () override |
| Method to cleanup resources used on shutdown. | |
| void | activate () override |
| Method to active Behavior and any threads involved in execution. | |
| void | deactivate () override |
| Method to deactivate Behavior and any threads involved in execution. | |
| Public Member Functions inherited from nav2_core::Behavior | |
| virtual | ~Behavior () |
| Virtual destructor. | |
| virtual CostmapInfoType | getResourceInfo ()=0 |
| Method to determine the required costmap info. More... | |
Protected Member Functions | |
| bool | getCurrentPoseChecked (geometry_msgs::msg::PoseStamped &pose) |
| Get one checked robot pose in the local frame, preserving the TF timestamp. More... | |
| void | execute () |
| void | stopRobot () |
Protected Attributes | |
| nav2::LifecycleNode::WeakPtr | node_ |
| std::string | behavior_name_ |
| std::unique_ptr< nav2_util::TwistPublisher > | vel_pub_ |
| ActionServer::SharedPtr | action_server_ |
| std::shared_ptr< nav2_costmap_2d::CostmapTopicCollisionChecker > | local_collision_checker_ |
| std::shared_ptr< nav2_costmap_2d::CostmapTopicCollisionChecker > | global_collision_checker_ |
| nav2::TransformBuffer::SharedPtr | tf_ |
| double | cycle_frequency_ |
| double | enabled_ |
| std::string | local_frame_ |
| std::string | global_frame_ |
| std::string | robot_base_frame_ |
| double | transform_staleness_threshold_ {0.0} |
| rclcpp::Duration | elapsed_time_ {0, 0} |
| rclcpp::Clock::SharedPtr | clock_ |
| rclcpp::Logger | logger_ {rclcpp::get_logger("nav2_behaviors")} |
Detailed Description
template<typename ActionT>
class nav2_behaviors::TimedBehavior< ActionT >
Definition at line 66 of file timed_behavior.hpp.
Member Function Documentation
◆ configure()
template<typename ActionT >
|
inlineoverridevirtual |
- Parameters
-
parent pointer to user's node name The name of this planner tf A pointer to a TF buffer costmap_ros A pointer to the costmap
Implements nav2_core::Behavior.
Definition at line 114 of file timed_behavior.hpp.
◆ getCurrentPoseChecked()
template<typename ActionT >
|
inlineprotected |
Get one checked robot pose in the local frame, preserving the TF timestamp.
- Parameters
-
pose Pose to reuse throughout the current run initialization or cycle
- Returns
- False if the transform is missing or stale; pose is unchanged on failure
Definition at line 183 of file timed_behavior.hpp.
The documentation for this class was generated from the following file:
- nav2_behaviors/include/nav2_behaviors/timed_behavior.hpp
